 Apparel & Accessories
 Vehicles & Parts
 Toys & Games
 Sporting Goods
 Office Supplies
 Luggage & Bags
 Home & Garden
 Hardware
 Furniture
 Copied
Go to and paste the code at the checkout to enjoy
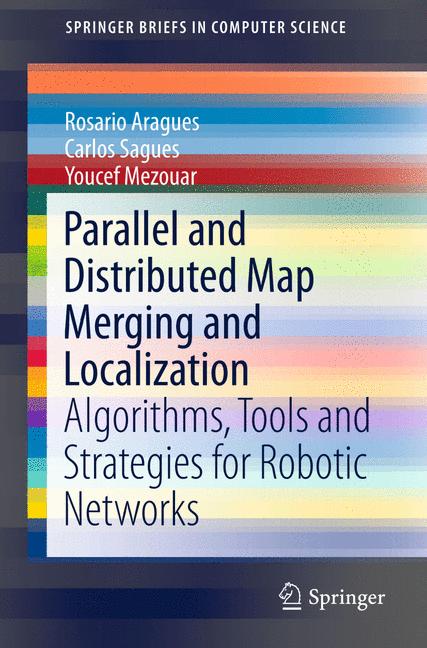
Parallel and Distributed Map Merging and Localization
Best Price:
Buy Parallel and Distributed Map Merging and Localization for $39.99 at @ Link.springer.com
No coupon is required — this is the standard retail price.
Set a price drop alert to never miss an offer.
Price Comparison
| Seller | Contact Seller | List Price | On Sale | Shipping | Best Promo | Final Price | Volume Discount | Financing | Availability | Seller's Page |
|---|---|---|---|---|---|---|---|---|---|---|
|
BEST PRICE 1 Product Purchase
|
|
$39.99 | $39.99 |
|
$39.99 | See Site | In stock | Visit Store |
Product Details
This work examines the challenges of distributed map merging and localization in multi-robot systems, which enables robots to acquire the knowledge of their surroundings needed to carry out coordinated tasks. After identifying the main issues associated with this problem, each chapter introduces a different distributed strategy for solving them. In addition to presenting a review of distributed algorithms for perception in localization and map merging, the text also provides the reader with the necessary tools for proposing new solutions to problems of multi-robot perception, as well as other interesting topics related to multi-robot scenarios. The coverage is largely self-contained, supported by numerous explanations and demonstrations, although references for further study are also supplied. The reader will not require any prior background knowledge, other than a basic understanding of mathematics at a graduate-student level.
Reviews
Questions & Answers

Humanitarian Intervention and Safety Zones
$39.99
A Holistic Approach to Ship Design
$149.00
An Introduction to Mathematical Modeling of Infectious Diseases
$39.99
Optical Fiber Sensors
$39.99
Women and Political Insurgency
$169.99
Mechanical Self-Assembly
$109.99
Quantitative Security Risk Assessment of Enterprise Networks
$54.99
Das Wesen des Gubetons
$59.99
Frankreich: Geschichte, Gesellschaft, Politik
$64.99
Asymptotic Theory of Elliptic Boundary Value Problems in Singularly Perturbed Domains Volume II
$169.99
Biometric Recognition
$79.99
Flexible Automation and Intelligent Manufacturing: The Human-Data-Technology Nexus
$379.99
Friedenserziehung
$19.99
Computational Methods and Models for Transport
$109.00
Victimology
$59.99
Supply Chain Controlling
$37.99
Lsungsbuch zur Einfhrung in die Festigkeitslehre
$44.99
Fine Needle Aspiration Cytology
$169.99
Mathematical Analysis I: Approximation Theory
$109.99
Problemlsendes Handeln in der Ausbildung von Bankkaufleuten
$49.99
Fortschritte der Chemie Organischer Naturstoffe / Progress in the Chemistry of Organic Natural Produ
$39.99
Englische Weltpolitik in englischer Beleuchtung
$59.99
Die wirtschaftlich trainierte Fra?
$59.99
Persnlichkeit und Computer
$59.99
Options for Swing Trading
$89.99
Diameter-Transformed Fluidized Bed
$199.99
Total Quality Management
$109.99
Reconfigurable Intelligent Surface-Empowered
$199.99
Empirische Forschung und Soziale Arbeit
$49.99
Protestant-Catholic Conflict from the Reformation to the 21st Century
$109.99
Peer-Interaktion in Abhngigkeit von familiren und auerfamiliren Bindungserfahrungen
$59.99
Complexity and Sustainability in Megaprojects
$219.99
Algebraic Inequalities
$44.99
A Finite Element Primer for Beginners
$79.99
Grenzen der klassischen Zinsbuchsteuerung im Licht der Niedrig-und Negativzinsphase
$49.99
Metal-Metal Bonds and Clusters in Chemistry and Catalysis
$169.99
Japanese Human Resource Management
$129.99
The Structure of Physics
$129.00
Exchange Rates and Macroeconomic Dynamics
$109.99
Druckrohrleitungen neuzeitlicher Wasserkraftwerke
$59.99

