 Apparel & Accessories
 Vehicles & Parts
 Toys & Games
 Sporting Goods
 Office Supplies
 Luggage & Bags
 Home & Garden
 Hardware
 Furniture
 Copied
Go to and paste the code at the checkout to enjoy
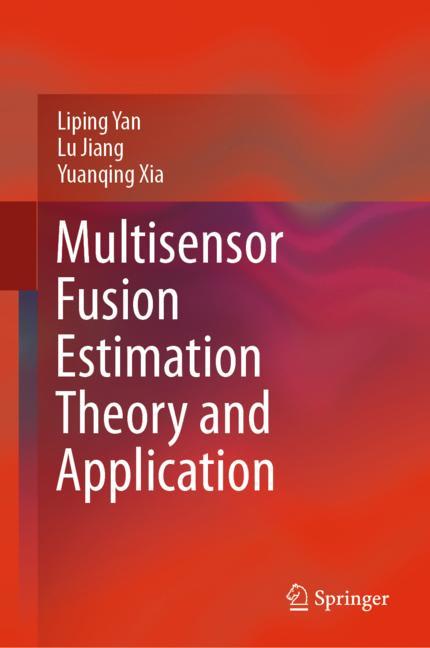
Multisensor Fusion Estimation Theory and Application
Best Price:
Buy Multisensor Fusion Estimation Theory and Application for $129.00 at @ Link.springer.com
No coupon is required — this is the standard retail price.
Set a price drop alert to never miss an offer.
Price Comparison
| Seller | Contact Seller | List Price | On Sale | Shipping | Best Promo | Final Price | Volume Discount | Financing | Availability | Seller's Page |
|---|---|---|---|---|---|---|---|---|---|---|
|
BEST PRICE 1 Product Purchase
|
|
$129.00 | $129.00 |
|
$129.00 | See Site | In stock | Visit Store |
Product Details
This book focuses on the basic theory and methods of multisensor data fusion state estimation and its application. It consists of four parts with 12 chapters. In Part I, the basic framework and methods of multisensor optimal estimation and the basic concepts of Kalman filtering are briefly and systematically introduced. In Part II, the data fusion state estimation algorithms under networked environment are introduced. Part III consists of three chapters, in which the fusion estimation algorithms under event-triggered mechanisms are introduced. Part IV consists of two chapters, in which fusion estimation for systems with non-Gaussian but heavy-tailed noises are introduced. The book is primarily intended for researchers and engineers in the field of data fusion and state estimation. It also benefits for both graduate and undergraduate students who are interested in target tracking, navigation, networked control, etc.
Reviews
Questions & Answers

Pesticides Bioremediation
$169.99
Salt Tectonics
$219.99
Betriebswirtschaftliche Warentypologie
$59.99
Fluid-Structure Interaction of Composite Structures
$299.99
Elemente der Sechsten Nebengruppe Uran
$64.99
Human Behavior Understanding
$39.99
Motorradtechnik
$59.99
Attacks and Defenses for the Internet-of-Things
$59.99
Environment, Modernization and Development in East Asia
$54.99
Contaminated Soil
$84.99
Introduction to Digital Filters
$44.99
Emotions in Transmigration
$54.99
Die Hohe Schule des Total Quality Management
$34.99
A Tissue Regeneration Approach to Bone and Cartilage Repair
$109.99
Open Data Politics
$54.99
Chaotic Logic
$109.99
Planung in der Krise?
$29.99
Zen Shorts (A Stillwater and Friends Book) by Jon J Muth
$18.99
Landscape, Association, Empire
$159.99
Chiral Liquid Chromatography
$39.99
Severe Asthma in Children and Adolescents
$99.99
Anthocyanins and Human Health: Biomolecular and therapeutic aspects
$39.99
IgM and Its Receptors and Binding Proteins
$119.00
Psycho-social Career Meta-capacities
$84.99
Environmental Problems of Central Asia and their Economic, Social and Security Impacts
$169.00
Phonon Scattering in Condensed Matter V
$84.99
Qualittsmanagement in der frhkindlichen Bildung, Erziehung und Betreuung
$39.99
Regional Science: Perspectives for the Future
$39.99
British Politics and European Elections 1994
$59.99
Protein Engineering
$129.99
Webdesign fr Studium und Beruf
$29.99
Niobium Alloys and Compounds
$39.99
Advisory Work in Crop Pest and Disease Management
$109.99
The Change Laboratory
$49.99
Complex Cases in Structural Heart Intervention
$249.99
Laser Communication with Constellation Satellites, UAVs, HAPs and Balloons
$139.00
Chiral Separations
$84.99
Trace Elements from Soil to Human
$219.99
Vordere Kreuzbandlsion
$79.99
Semantic 3D Object Maps for Everyday Robot Manipulation
$109.99

